INTERACTIVE ROBOT TOURWalter.
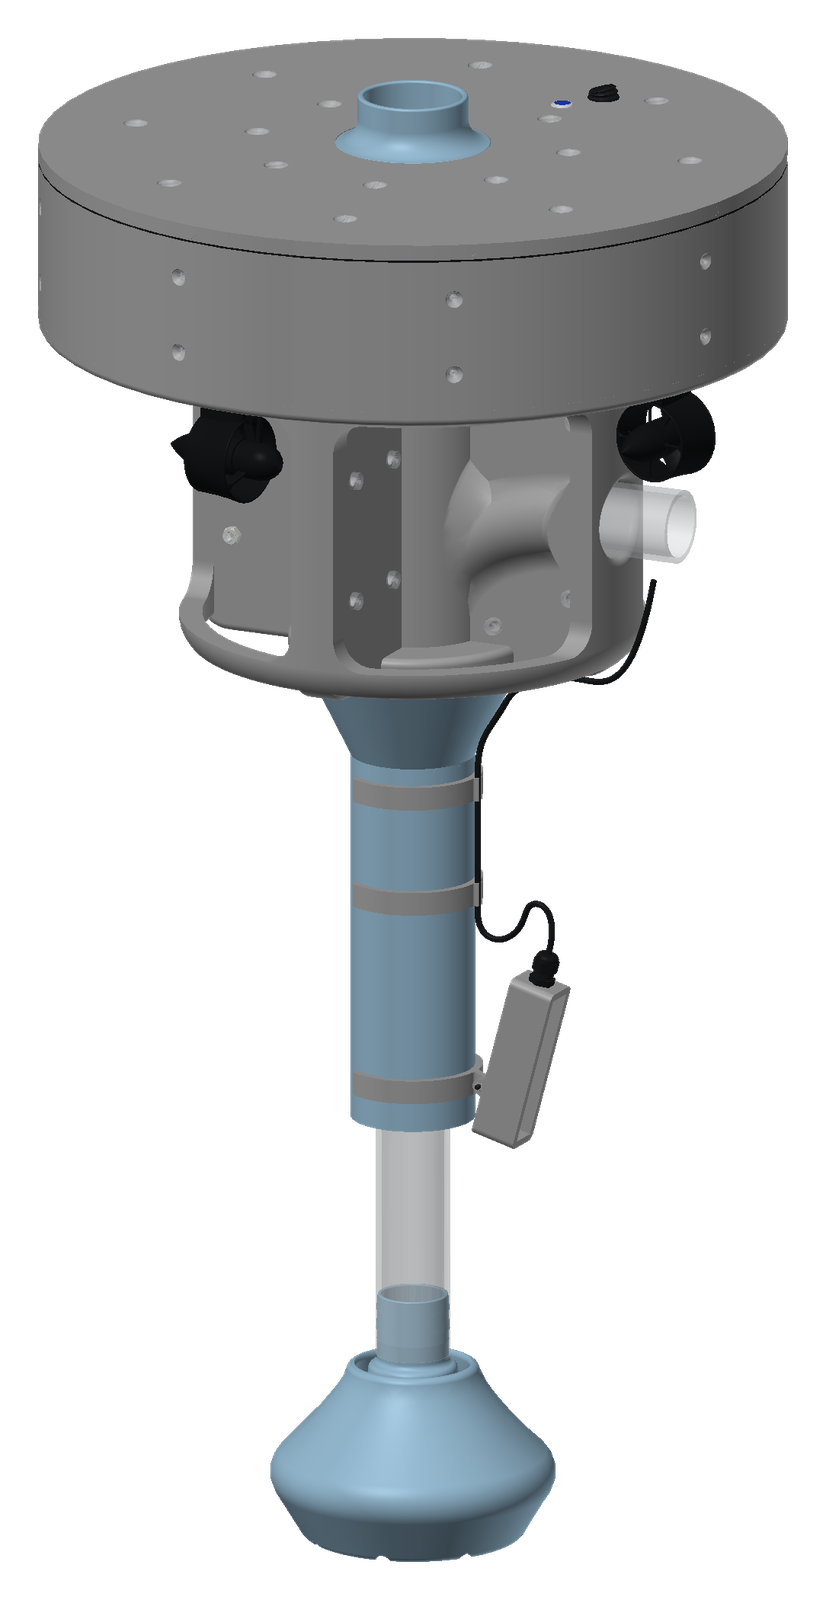
0%
Drag to rotate · Tap + to explore
↻ 0°
Machined bearing housingBearing plates and machining drawingMachined bearing componentsAssembled bearing interfaceBearing mounted in the printed structure THE COMPONENTS
A closer look.
Bearing geometry · original component geometry01 / BEARING GEOMETRYTwo races. One interface.
Inner and outer races form the rotating interface between the robot assemblies.
Inner RaceOuter Race
PTFE interfaces · original component geometry02 / PTFE INTERFACESMaterial where motion meets structure.
PTFE bushings and a ring separate moving surfaces.
PTFE BushingPTFE Ring (3D Printed)
Assembly fit · original component geometry03 / ASSEMBLY FITAlignment through the stack.
The spacer and mounting hardware align the bearing with the printed body.
BIG SpacerBearing Mounting Hardware